Discussions on vehicle safety, automotive development methodologies and future research collaboration were at the centre of a visit to the Department of Automotive Technologies by researchers from Karlsruhe Institute of Technology (KIT). The regular professional meetings, held annually since 2022, aim to facilitate the exchange of research experience and identify opportunities for joint research.
The Department of Automotive Technologies at Budapest University of Technology and Economics (BME) welcomed Prof. Dr. Eric Sax and Marc Schindewolf from the Institute for Information Processing Technology (Institut für Technik der Informationsverarbeitung, ITIV) at Karlsruhe Institute of Technology (KIT). During the visit, both teams presented their current research topics and development plans, focusing in particular on vehicle safety, methodologies for automotive development, and intelligent transport solutions.
An important part of the discussions was devoted to exploring opportunities for future collaboration. The participants discussed expanding researcher and academic staff exchanges, preparing joint research projects, and identifying opportunities for joint publications and conference participation.
Identifying Concrete Areas for Collaboration
The discussions resulted in several potential areas for joint activities. These include coordinated control of Unimog vehicles, continued researcher exchanges – for example, through winter school visits or semester-long research stays – and joint participation in the Enhanced Safety for Vehicles – Student Safety Technology Design Competition (SSTDC). The participants also explored opportunities for broader cooperation related to ICM.
These regular professional meetings enable researchers from both institutions to learn about each other’s work and expertise, providing a basis for developing new joint research directions.
Representing BME’s Department of Automotive Technologies, the meeting was attended by Dr. Árpád Török, Head of the Safety and Security Research Group, as well as Roland Nagy, Gábor Lóránt, Bálint Kovács and Tamás Kazár.
At the conclusion of the visit, both teams reaffirmed their commitment to continuing the collaboration and advancing the research opportunities identified during the discussions.
https://auto.bme.hu/wp-content/uploads/2026/10/Team_photo-.jpg15361920Bognár Bertalan/wp-content/uploads/2024/07/bme-at_logo_white_en01.svgBognár Bertalan2026-10-15 18:13:342026-10-15 18:13:34Researchers from Karlsruhe Institute of Technology Visit the Department
Transport infrastructure is not necessarily just the environment in which vehicles operate: with appropriate sensing, data processing and a digital twin, the road itself can become an active, intelligent part of the mobility system. This was the subject of a presentation by Dr. Zsolt Szalay, Associate Professor and Head of the BME Department of Automotive Technologies, at the 15th Regional Automotive Supplier Conference, where the Department also welcomed participants with a live VR demonstration of the M1–M7 smart road digital twin.
The BME Department of Automotive Technologies actively participated in the 15th Regional Automotive Supplier Conference organised by QFD Group in Budapest on 29–30 September 2026. The event brings together automotive decision-makers, OEMs and Tier 1–2 suppliers, as well as representatives of engineering, development and management functions. In addition to industry trends and technological and quality-related challenges, the two-day programme placed strong emphasis on the automotive solutions of the future.
The Department’s participation focused on intelligent transport infrastructure and the digital twin of the M1–M7 smart road. Dr. Zsolt Szalay delivered the conference’s opening plenary presentation, entitled “When the Road Starts Thinking – The Role of Intelligent Transport Infrastructure in Automated Mobility.” In connection with the presentation, participants could also experience the real-time digital twin of the M1–M7 smart road section in a VR environment throughout the day.
What happens when not only the car sees the road?
Dr. Szalay’s presentation started with a simple question: Who sees the road?
For road users, it seems natural that the driver, or the vehicle, perceives the environment. The vehicle’s cameras, radars and LiDAR sensors observe the world around it and use this data to build a model of the traffic situation. This approach, however, has an inherent limitation: the vehicle can primarily work with what it is able to perceive from its own position.
A larger vehicle can obscure the traffic ahead. A bend or a roadside object can conceal an event farther down the road, while in an urban environment, a building may obstruct the detection of a traffic situation developing across an intersection.
What would change if the infrastructure itself could also perceive traffic?
A suitably sensor-equipped road section can observe traffic from a different perspective. Rather than seeing only the immediate surroundings of a single vehicle, it can observe events across an entire road section and process data from different sensors together. This can provide information about traffic situations developing hundreds of metres farther ahead or behind.
This change in perspective leads to the concept of intelligent infrastructure: a public road is not merely the physical environment of vehicles, but can also become part of the sensing and information layer of the mobility system.
The M1–M7 as a real-world research platform
The practical implementation of this concept is demonstrated by the M1–M7 smart road project, in which the BME Department of Automotive Technologies and Magyar Közút equipped an approximately 1.5-kilometre road section with a high-density sensing system.
The road section combines three types of sensing technology: 23 LiDAR sensors, 26 RGB cameras, 10 radar sensors and 10 thermal cameras monitor the traffic environment. The system generates approximately 25 gigabit of data per second, meaning that the data cannot be processed by relying exclusively on a centralised cloud infrastructure. Edge computing capacity deployed along the road complements the cloud-based architecture.
The concept is not limited to data originating from the infrastructure, either. The system can also integrate information from vehicle sensors using wireless communication. This allows the environment perceived by the infrastructure and that perceived by vehicles to become part of a common information system.
In developing the system, the Department also applies standardised data models and communication solutions, including solutions related to the ADASIS and SENSORIS standard families.
From data to a digital twin
One of the most important outcomes of the system is the digital representation of the real road section – the digital twin.
A digital twin is not simply a three-dimensional model. In the case of the M1–M7, real-time detected traffic objects are placed within a highly accurate, static map environment. The static map was created using laser scanning and provides a centimetre-level geometric representation of the road section. On top of this, a dynamic layer of continuously changing traffic information is added.
The physical structure of the road and the traffic taking place on it can therefore be represented simultaneously within the digital environment.
One of the system’s important characteristics is its real-time operation. The Department applies its own artificial-intelligence-based sensor-fusion and vehicle-detection solutions. Information from the different sensors is fused at several levels, and the system can detect vehicles across the entire road section in approximately 30 milliseconds. The complete processing cycle currently takes around 100 milliseconds, allowing the full situation picture to be updated twenty times per second.
This speed enables the digital twin to be more than a retrospective data visualisation: it becomes a system that remains temporally connected to the real traffic situation.
The intelligent road as a digital laboratory
According to Dr. Szalay, one of the most important potential applications of such infrastructure is testing.
Automated-driving and driver-assistance systems are currently typically developed and validated in several stages: in simulation environments, on test tracks and finally in real-world traffic. Real-world traffic testing, however, is costly and time-consuming, while rarely occurring but important traffic situations are difficult to reproduce in a controlled and repeatable manner.
Intelligent infrastructure offers a new possibility here. The M1–M7 smart road can provide highly accurate ground truth, or reference information, in a real traffic environment. This makes it possible, for example, to validate the perception of driver-assistance systems in real time.
The digital twin can take this one step further: real traffic situations can be replayed, repeated and modified virtually. Automated-driving functions under development can therefore be examined not only in simulated, artificial environments, but also using a digital representation of a real road section and real traffic.
In this model, physical and virtual testing are not alternatives to one another, but complementary methods that reinforce each other.
The Department is already investigating this possibility in international collaborations: using simulators at partner universities, it is possible to connect to the current traffic environment of the M1–M7 road section, while the simulated vehicle perceives the representation of real traffic within the digital environment.
The road that remembers
Continuous data collection gives infrastructure another important capability: the road can not only see, but also remember.
If the traffic on a road section is observed over an extended period, the result is not merely a series of isolated traffic events, but a collection of recurring patterns.
It becomes possible, for example, to observe how traffic changes on Monday mornings and Friday afternoons, how rain or fog affects traffic, where congestion regularly develops, and what kinds of traffic situations precede these events.
This makes it possible for the system not only to describe the current traffic state, but also to learn from recurring situations.
Based on large volumes of data, models can also be developed that, initially under human supervision and potentially in the longer term automatically, could support traffic interventions.
A New Dimension to Accident Investigation
A digital twin can also enable an approach to accident investigation that differs fundamentally from conventional on-site procedures. When continuously recorded data from multiple sources are available for the traffic environment, the precise course of an accident can not only be reconstructed afterwards, but its preceding events can also be reviewed and analysed. This means that an investigation does not have to rely exclusively on traces recorded after the accident, the vehicles involved, and witness statements: a digital twin can provide objective, time-stamped and retrievable information that offers a more precise picture of what happened in the seconds leading up to the accident and during the event itself. Another practical benefit could be that traffic restrictions and road closures required for on-site data collection could be partly or even entirely avoided. In this way, a digital-data-based approach to accident investigation could also reduce the time and cost losses resulting from traffic disruption caused by accidents.
We do not need an accident to happen in order to learn from it
One particularly important potential of the digital twin is that lessons do not have to be drawn exclusively from accidents that actually occur.
The same traffic situation can have several possible outcomes. A dangerous situation may lead to an accident on one occasion, while on another occasion the participants may avoid a collision. Such near-miss situations – incidents that almost resulted in an accident – can themselves contain valuable information.
In the M1–M7 system, continuous tracking of the movement of traffic objects makes it possible to identify and analyse such situations. In aviation safety, learning from near misses has long played an important role; intelligent road infrastructure could enable a similar approach in road transport.
Data collected over a longer period can also reveal where and why critical situations repeatedly develop on a particular road section. The knowledge gained in this way can be used not only in operating the given road section, but can also provide valuable input for future infrastructure development and design decisions.
The future cannot simply be predicted – but it can be recognised earlier
The next step discussed in the presentation was prediction.
According to Dr. Szalay, for an intelligent mobility system, the most important objective is not necessarily to “predict the future”. It may be much more important to identify as early as possible the patterns that are likely to lead to congestion, dangerous situations or other undesirable traffic events.
If a change can be detected early enough, intervention can also take place earlier and more preventively.
This is no longer simply traffic monitoring, but decision support: the infrastructure may not only know what is happening, but also indicate the direction in which the traffic situation is developing.
Infrastructure can also extend the capabilities of the car
The digital twin and intelligent infrastructure do not necessarily benefit only the most advanced vehicles.
One of the directions pursued by the Department is to make situation information originating from the infrastructure available through a mobile application also to vehicles that have less advanced sensing capabilities, or no such systems of their own.
Such a solution could, for example, display the position and movement of vehicles detected by the infrastructure even when the vehicle’s own sensors are blocked by another vehicle. This could open up new possibilities in areas such as blind-spot warnings, following-distance recommendations or speed recommendations designed to help prevent dangerous braking waves.
The system could also provide personalised traffic information. Instead of every road user receiving the same general message, the infrastructure could potentially formulate recommendations tailored to the position of individual vehicles.
The next stage of development could be reached when the mobility system not only provides information, but also takes an active role in optimising traffic – for example, by recommending a lane change to some vehicles and a change in speed to others.
New capabilities, new opportunities for suppliers
Technological development also raises an important question for the conference audience, particularly automotive suppliers.
In an intelligent mobility system, value is increasingly created not by individual components in isolation. Sensors, communication systems, computing capacity, artificial intelligence, digital twins and the services built on them jointly create new capabilities.
This may also transform the supplier ecosystem: a component increasingly becomes an enabler of a capability within a larger system.
The supplier of the future will therefore need to do more than deliver a component. Increasingly, suppliers will need to provide technological capabilities, expertise and solutions that can be integrated into a larger system and create value in their own right.
This is particularly important in emerging fields such as intelligent infrastructure, cooperative perception, digital twins, traffic data processing and automated mobility.
Entering the M1–M7 digital twin
Conference participants could not only hear about intelligent infrastructure in the presentation: at the BME Department of Automotive Technologies’ demonstration area, they could enter the M1–M7 smart road digital twin through a live VR demonstration.
Using VR headsets, visitors could move through the spatial environment of the digital representation of the road section, surrounded by vehicles and traffic events appearing in synchronisation with real-world traffic. The demonstration thus provided a direct experience of one of the digital twin’s essential characteristics: it is not a static 3D model, but a dynamically changing representation based on real-time data streams.
The VR demonstration was part of the QFD Group conference programme throughout the day in the exhibition area, directly complementing Dr. Szalay’s plenary presentation.
The road as an active part of the mobility system
The final message of Dr. Szalay’s presentation was that the development of automated mobility should not be viewed exclusively from the perspective of the vehicle.
Alongside increasingly intelligent vehicles, infrastructure itself can acquire capabilities for sensing, data processing, situation awareness, learning and decision support. The digital twin built on these capabilities can then create a shared information environment for vehicles, infrastructure, road users and service providers.
The next step, therefore, may not simply be an even smarter car.
We are increasingly moving towards a smarter mobility system.
The M1–M7 smart road and digital twin research programme of the BME Department of Automotive Technologies provides a research and demonstration platform for exploring this approach in a real traffic environment. The project simultaneously supports research into intelligent infrastructure, automated mobility, digital-twin-based validation and the future development of the mobility system.
https://auto.bme.hu/wp-content/uploads/2026/10/QFD_Day1_00015-b-.jpg15361920Bognár Bertalan/wp-content/uploads/2024/07/bme-at_logo_white_en01.svgBognár Bertalan2026-10-06 11:19:232026-10-08 17:10:50When the Road Starts Thinking – The BME Department of Automotive Technologies Presents the Future of Intelligent Transport Infrastructure at the QFD Conference
How can the performance of a driver assistance system be evaluated objectively without equipping the vehicle under test with specialized measurement equipment? Experiments conducted on the M1–M7 smart road section by the BME Department of Automotive Technologies explore this question by testing ACC and Lane Centering functions in real highway traffic, using a digital twin generated in real time from infrastructure sensor data.
Testing advanced driver assistance systems (ADAS) in a reliable and meaningful way is becoming increasingly complex. Functions such as Adaptive Cruise Control (ACC) and Lane Centering do not operate in isolation: they continuously respond to a dynamic and changing traffic environment. This makes it increasingly important to complement laboratory and closed proving-ground tests with methods that allow ADAS performance to be evaluated objectively and reproducibly under real road traffic conditions.
Researchers at the BME Department of Automotive Technologies conducted a series of tests on the M1–M7 smart road section to investigate the operation of ACC and Lane Centering in real highway traffic. The distinctive feature of the measurement environment was the simultaneous generation of a digital twin of the road section from the infrastructure’s sensor data in real time. The digital twin represented not only the test vehicles, but also the surrounding traffic with high accuracy.
A total of five test vehicles participated in the measurement campaign, three of which were also equipped with high-precision GNSS systems. These vehicles provided independent reference data for validating the accuracy of the digital twin, including vehicle position, speed, relative distance and motion trajectories.
The tests were conducted in both traffic directions and across all available lanes of the M1–M7 smart road section: four lanes in each direction, eight lanes in total. A key characteristic of the experiments was that they were carried out not in an isolated test environment, but alongside actual highway traffic.
This setting also allowed the researchers to observe not only predefined test scenarios, but naturally occurring and spontaneous traffic events.
“One of the key advantages of the digital twin is that it does not only see the test vehicle, but its entire traffic environment as well. This effectively provides an external reference that makes it possible to objectively evaluate the behaviour of ADAS systems in real traffic.” – Dr Zsolt Szalay, Head of the BME Department of Automotive Technologies
ACC Response in Controlled and Spontaneous Situations
Several traffic scenarios were developed to investigate Adaptive Cruise Control. In the initial scenarios, the lead vehicle travelled at a constant speed while the ACC system of the following vehicle regulated its speed according to the configured following conditions.
In further scenarios, the lead vehicle performed accelerations and decelerations of varying magnitude. These situations made it possible to analyse the response of the ACC system in detail, including the temporal evolution of following distance and relative speed, as well as how dynamically the system responded to changes in the speed of the vehicle ahead.
At the same time, real traffic introduced situations that could not be fully planned in advance. On several occasions, for example, a vehicle from the public traffic merged into the gap between the two test vehicles.
Although such events caused the measurements to deviate from the predefined test scenarios, they were particularly valuable from a research perspective. Such situations are much closer to the conditions that the ADAS system of a production vehicle may encounter in everyday traffic.
Because the infrastructure-based digital twin also tracks vehicles in public traffic, these spontaneous interactions can be reconstructed and analysed. This makes it possible to determine when, where and how the traffic situation changed, and how the ACC system responded to the new conditions.
Lane Centering: Making In-Lane Vehicle Motion Measurable
During the Lane Centering tests, the researchers analysed vehicle lane-keeping behaviour and in-lane trajectories. Based on the high-precision vehicle trajectories determined by the digital twin, the lateral position of the vehicle within its lane and its evolution over time can be evaluated.
This is particularly relevant for a function whose operation is primarily reflected in the continuous control of the vehicle’s lateral position. An infrastructure-based reference makes it possible to assess vehicle motion independently of the vehicle itself, using an external measurement system.
The approach therefore goes beyond simply “seeing” where a vehicle is travelling. The available data make it possible to quantify the vehicle’s position within the lane and how that position changes over time.
When Traffic Itself Becomes Part of the Test
One of the major challenges of conventional testing is that, in real road environments, other road users can change the conditions in unpredictable ways. In the present measurements, however, this characteristic of real traffic became one of the most interesting research opportunities.
In addition to the test vehicles, the digital twin represented the surrounding public traffic. As a result, an unexpected lane change, a change in speed or another traffic interaction was not simply an “unplanned event”, but became a measurable and analysable occurrence.
“Spontaneous interactions in real traffic do not necessarily disrupt a test – in many cases, they can provide valuable data. With the help of the digital twin, we can also analyse situations that develop unexpectedly during test execution.” – Dr András Rövid, Head of the Cooperative Perception Research Group
This approach can be particularly important for evaluating highly complex ADAS functions, where system behaviour is often determined by interactions involving multiple vehicles and continuously changing traffic situations.
Digital Twin as a Vehicle-Independent Measurement Reference
One of the key objectives of the experiments was to demonstrate that a digital twin generated in real time from infrastructure sensor data can be used to evaluate ADAS functions against an external, vehicle-independent reference.
The three GNSS-equipped test vehicles provided high-precision reference data that enabled the researchers to verify how accurately the digital twin could determine vehicle positions, speeds, relative distances and trajectories.
The significance of this approach is that, in the longer term, it may eliminate the need to equip every vehicle under test with specialized high-precision GNSS measurement systems in order to obtain objective measurement data.
If infrastructure can reconstruct the motion of traffic participants with sufficient accuracy and in real time, the road itself – more precisely, its intelligent sensor network and the digital twin generated from it – can serve as an external measurement reference system.
This opens up new possibilities for testing ADAS systems on a larger number of vehicles in real road environments. The approach makes it possible to analyse the motion of multiple vehicles simultaneously, the interactions between them, and the responses of driver assistance systems to these interactions.
One Step Closer to Scalable ADAS Testing
The experiments conducted on the M1–M7 smart road section therefore represent more than the evaluation of individual ACC and Lane Centering functions. They also demonstrate a testing and evaluation concept in which real-time infrastructure sensor data, a digital twin and the operation of vehicle-based driver assistance functions are integrated into a common system.
One of the most promising aspects of this approach is its potential to reduce the need for specialized vehicle-side measurement equipment, while enabling the collection of large volumes of objective and comparable test data.
This could become particularly important as ADAS functions and automated driving systems continue to evolve and increasingly complex real-world traffic situations need to be measured, evaluated and compared.
From this perspective, the M1–M7 smart road section is more than an intelligent road. It provides a research environment in which the sensing capabilities of road infrastructure can be directly connected to the objective evaluation of vehicle behaviour – bringing the testing of ADAS functions one step closer to scalable, infrastructure-based validation in real traffic.
https://auto.bme.hu/wp-content/uploads/2026/09/M1M7_ADAS_tesz-1.jpg15361920Bognár Bertalan/wp-content/uploads/2024/07/bme-at_logo_white_en01.svgBognár Bertalan2026-09-01 17:02:312026-09-01 17:02:31When the Road “Sees” the Vehicle – Testing ADAS with a Digital Twin in Real Highway Traffic
The BME Department of Automotive Technologies–affiliated spin-off company DriveByCloud has achieved significant progress in the development of an automated ADAS test execution framework. During a test campaign conducted at the ZalaZONE Proving Ground, the development team successfully continued the system integration activities supporting the realization of automated, repeatable, and efficient vehicle testing processes.
Between 28–30 July 2026, DriveByCloud experts conducted a test campaign at the ZalaZONE Proving Ground with the aim of further developing and integrating the automated ADAS (Advanced Driver Assistance Systems) test execution framework.
The goal of the development is to create a comprehensive system capable of the automated preparation, execution, evaluation, and documentation of ADAS testing processes. During the campaign, two mobile sensor stations equipped with multimodal sensor systems were deployed in the ZalaZONE Smart City module. These stations enabled the system to accurately detect and record the movements of both the test vehicle and the moving platform equipped with a pedestrian dummy involved in the test scenarios.
One of the key capabilities of the developed framework is its ability to import predefined test scenarios and automatically generate scenario variants by modifying different parameters, such as vehicle speed or event timing. The test scenarios to be executed can then be organized into an execution list with predefined numbers of repetitions.
Following test execution, the system automatically evaluates the movement of the vehicle and target objects, as well as the distances between them, based on raw sensor data and user-defined evaluation criteria. Individual test reports are generated based on the evaluated data, providing detailed documentation of each test run. The system then automatically returns the test assets to their initial positions and starts the execution of the next scenario. Summary reports for each scenario type enable efficient statistical analysis of the measured results.
“During the test campaign, we achieved significant progress in system integration. The experience gained greatly supports our further development activities and provides valuable feedback on the practical applicability of automated ADAS test execution processes,” said Zsolt Vincze, scientific assistant at the Autonomous Vehicles Research Group operating within BME Automated Drive and Managing Director of DriveByCloud Ltd.
The test campaign was conducted by DriveByCloud within the framework of a project supported by the National Research, Development and Innovation Office (NKFIH). The work was supported by the expertise and professional collaboration of specialists from the ZalaZONE Proving Ground, the Department of Control for Transportation and Vehicle Systems at BME, and HUN-REN SZTAKI.
This development represents another important step toward automated vehicle testing processes, contributing to the faster, more reliable, and more objective validation of advanced driver assistance systems.
https://auto.bme.hu/wp-content/uploads/2026/08/Meres.jpg15361920Bognár Bertalan/wp-content/uploads/2024/07/bme-at_logo_white_en01.svgBognár Bertalan2026-08-06 17:11:092026-08-06 17:11:09Significant Progress in Automated ADAS Test Execution Framework Development by DriveByCloud
The Safety First! 2026 transportation safety competition, organized for the fourth consecutive year by the Department of Automotive Technologies at the Budapest University of Technology and Economics (BME) and its Safety and Security Research Group, has successfully concluded. At this year’s final round, student teams presented the research and development results they had been working on throughout the semester, offering innovative responses to real-world vehicle safety challenges.
Since its launch, the goal of the Safety First! competition has been to provide students with an opportunity to work on real engineering problems while developing their professional skills with both academic and industrial support. Throughout the multi-stage competition, participants are expected not only to develop technically sound concepts, but also to demonstrate their applicability and present their results in a professional manner.
In the final round, projects were evaluated by an expert jury based on five key criteria: the quality of the abstract, the technical standard of the documentation, the level of innovation, project maturity, and the quality of the oral presentation.
Innovative Solutions for the Future of Vehicle Safety
This year’s competition once again reflected the technological diversity of today’s automotive industry, covering topics ranging from vehicle dynamics and artificial intelligence to driver monitoring systems and the verification of safety-critical functions.
🥇 1st Place – Squadron
Reinforcement Learning Based Oversteer Control Under Dynamically Changing Adhesion
The winning team introduced a hybrid Model Predictive Control (MPC) and Reinforcement Learning-based vehicle stability solution capable of adaptive intervention under rapidly changing road adhesion conditions. The system supports safe vehicle control through real-time decision-making and demonstrates promising applicability in advanced driver assistance systems (ADAS) and fleet-level safety applications.
🥈 2nd Place – NOVA
Neural Optimization for Verified Automotive Safety
The second-place project addressed a particularly timely challenge: how to reconcile the performance of neural networks with the strict verification requirements of automotive safety-critical systems. The team presented an innovative concept combining the trainability of AI-based vehicle functions with validation and certification considerations.
🥉 3rd Place – OrbitDMS
Modelling Multi-Sensor Fusion for Driver Monitoring System for Takeover Readiness
The third-place team focused on one of the key challenges of partially automated driving: how to reliably determine whether a driver is ready to take back control of the vehicle. Their multi-sensor fusion approach could contribute to safer transitions between automated and manual driving.
Real Industry Perspective, Practical Experience
The competition once again demonstrated that students are capable of addressing today’s automotive challenges at a remarkably high professional level. The presented projects stood out not only for their technical depth and practical relevance, but also for the mature, systems-level engineering mindset demonstrated by the participants.
“One of the greatest strengths of the Safety First! competition is that it gives students the opportunity to challenge themselves in an environment that closely resembles real industrial development processes. Beyond technical content, problem definition, high-quality documentation, and professional presentation skills are equally important,” highlighted Tamás Kazár, chief organizer of the competition and PhD researcher of the Safety and Security Research Group at the BME Department of Automotive Technologies.
Acknowledgements to Our Supporters and Jury Members
This year’s competition was once again supported by our industrial partner, Bosch, whose expert involvement provided students with direct insight into industrial expectations and development perspectives.
We would also like to express our sincere appreciation to the members of the professional jury for their valuable feedback and dedicated work:
Réka Jenei (Bosch)
Tamás Kazár (BME KJK, Safety and Security Research Group)
Árpád Török (BME KJK, Head of the Safety and Security Research Group)
We warmly congratulate all participants for their hard work and dedication, and especially the finalist teams for their outstanding achievements.
Over the past four years, the Safety First! competition has evolved into a unique professional platform where students not only compete, but also develop genuine engineering thinking, presentation skills, and an industry-oriented mindset. We are already looking forward to the innovative ideas and new challenges of next year’s competition.
https://auto.bme.hu/wp-content/uploads/2026/06/The_Winners_2026-.jpg15361920Bognár Bertalan/wp-content/uploads/2024/07/bme-at_logo_white_en01.svgBognár Bertalan2026-06-04 13:13:282026-06-04 13:13:28Safety First! 2026 – Transportation Safety Innovation Competition Concludes for the Fourth Time
Hungarian-developed technology gains U.S. patent protection for enabling vehicle control even during skidding
The United States Patent and Trademark Office (USPTO) has granted patent protection to a vehicle control technology developed by researchers at the Department of Automotive Technologies of the Budapest University of Technology and Economics (BME). This internationally outstanding innovation is unique in its ability to maintain controlled vehicle maneuverability beyond the limits of tire adhesion, even while skidding, significantly reducing the risk of run-off-road accidents.
The development had previously been granted unitary patent protection in Europe; however, obtaining the U.S. patent marks another major milestone in the international recognition of the technology. The USPTO’s decision also signals that the Hungarian researchers’ solution is considered both novel and industrially relevant on a global scale.
Developed by the Vehicle Dynamics and Control Research Group operating within the BME Automated Drive Lab, the technology introduces a fundamentally new approach to vehicle safety. While conventional stability control systems – such as Electronic Stability Program (ESP) – primarily aim to restore traction, this new technology maintains vehicle controllability even in a skid condition. When necessary, the system can take over control from the driver and guide the vehicle back to a safe trajectory during a loss of traction, even by applying a controlled drift maneuver if required.
“A significant share of road accidents occurs because, in critical situations, the driver is no longer able to control the vehicle’s motion. Our objective was to maintain controllability close to, or even beyond, the physical limits of adhesion,” said Dr. Zsolt Szalay, Head of the Department of Automotive Technologies at BME. He added: “The U.S. patent not only validates the scientific value of this development but also demonstrates that world-class, industrially significant automotive research is taking place in Hungary.”
The technology may be particularly important for the vehicles of the future, as one of the key safety challenges for automated and autonomous systems is how they handle extreme traffic situations involving loss of traction. As such, the development could contribute not only to improved road safety but also open new opportunities in the advancement of next-generation vehicle control systems.
In recent years, the Department of Automotive Technologies at BME has participated in numerous internationally recognized research and industrial collaborations in the fields of automated vehicles, vehicle dynamics, functional safety, and future mobility systems. The newly granted U.S. patent is yet another example of how Hungarian engineering and scientific expertise can produce innovations that are competitive at the international level.
The Department of Automotive Technologies and BME Automated Drive Lab is participating as both exhibitor and speaker at the TRA 2026 conference in Budapest, with a strong focus on the M1–M7 smart motorway section and its real-time digital twin system. During the multi-day international event, our researchers present the latest results in connected and automated mobility through interactive VR demonstrations and several technical presentations.
Budapest hosts the Transport Research Arena (TRA 2026), one of Europe’s most important conferences in transport research and innovation, bringing together around 3,000 participants including researchers, industry experts, and decision-makers to discuss the future of mobility.
The BME Department of Automotive Technologies participates as a guest of the Hungarian Public Road Nonprofit Ltd. (Magyar Közút) at its exhibition stand, where the focus is on presenting the M1–M7 smart motorway section and the associated real-time digital twin system. An interactive VR-based demonstration is also available at the stand, providing visitors with an immersive experience of the developed system and its capabilities in representing real-world traffic environments.
Beyond the exhibition presence, the department is strongly represented in the technical programme, with researchers contributing to several thematic sessions throughout the conference. The presentations focus on testing connected and automated transport systems, sensor fusion and V2X-based risk assessment, next-generation traffic management concepts, and the role of real-time digital twins in enhancing transport safety and efficiency.
Together, these contributions highlight how real-time digital twin technology based on live traffic data is reshaping the development and validation of future transport systems, both in highway environments and in complex mixed-traffic scenarios.
The scientific contributions of the department are coordinated by Dr. Zsolt Szalay, Head of the Department of Automotive Technologies at BME, who also delivers several keynote and invited talks at the conference. Reflecting on the event, he noted:
“After our demonstrations and presentations, we received extensive feedback that digital twin technology is setting new foundations for transport systems. The real-time system we have developed not only enhances modelling accuracy, but also redefines how safety and efficiency in transportation can be understood.”
The participation of BME at TRA 2026 demonstrates the department’s growing international impact in the development of next-generation mobility systems, particularly in the fields of digital twins and connected infrastructure-based solutions.
https://auto.bme.hu/wp-content/uploads/2026/05/Stand.jpg15371920Bognár Bertalan/wp-content/uploads/2024/07/bme-at_logo_white_en01.svgBognár Bertalan2026-05-20 17:19:582026-05-20 17:19:58BME Automated Drive at TRA 2026 in Budapest – focusing on the digital twin and the M1–M7 smart road
The student team of the Vehicle Safety and Cybersecurity Research Group (VSSRG), affiliated with the Department of Automotive Technologies at the Budapest University of Technology and Economics (BME) and operating within the BME Automated Drive Laboratory, participated as a European finalist in one of the world’s most prestigious vehicle safety forums. The team took part in the final round of the Student Safety Technology Design Competition (SSTDC), held within the framework of the Enhanced Safety of Vehicles (ESV) Conference in Toronto, Canada. In addition to competing in the student competition, the team also represented BME through a scientific presentation and as exhibitors at the conference expo.
The 28th Enhanced Safety of Vehicles (ESV) Conference took place in Toronto between May 12–15, 2026, serving as one of the most important international forums in the field of vehicle safety. The event was jointly organized by the National Highway Traffic Safety Administration (NHTSA) of the United States Department of Transportation and Transport Canada, bringing together leading experts, researchers, and industry stakeholders in vehicle safety, automated mobility, and transport innovation.
At the conference, the BME Automated Drive Vehicle Safety and Cybersecurity Research Group (VSSRG) student team represented the Department of Automotive Technologies as a European finalist in the final round of the 10th Student Safety Technology Design Competition.
The team reached the final with their project titled “When Cars Talk: V2X-Powered Risk Metrics to Improve Next-Generation Intersection Safety”, competing in the Advanced Driver Assistance Systems (ADAS) category.
The project focuses on reducing complex accident risks at road intersections, which are among the most critical hotspots in road safety. The concept is based on vehicle-to-everything (V2X) communication, enabling real-time cooperative risk assessment that complements traditional onboard sensor-based systems. This approach is particularly aimed at improving safety in dense urban traffic environments and scenarios with limited visibility.
Team members:
Abdulagha Dadashev
Roland Nagy
Tamás Márton Kazár
Zsombor Pethő, PhD (team leader and supervisor)
During the conference plenary session, the project was presented to an international audience by Roland Nagy.
Representing BME in multiple roles
The team’s participation in Toronto went beyond the student competition itself. In addition to competing in the final, they also contributed to the scientific program with a technical presentation and showcased their research activities as exhibitors at the conference expo.
This multi-role participation provided not only a competitive platform, but also direct networking opportunities with leading actors in vehicle safety and cybersecurity, as well as insight into the latest technological and research directions in the field.
A deliberately built student innovation ecosystem
Reaching the final was the result of an intensive development process spanning more than a year. Since early 2025, the student team has been working on developing their concept, achieving several key milestones on the path to international recognition.
Behind this success stands the innovation ecosystem built by the VSSRG research group and the Safety First! student competition organized at the department, which provides students with the opportunity to address real-world traffic safety challenges and develop internationally competitive solutions.
“We are particularly proud that our students were able to represent BME in such a high-level international field, where the future of vehicle safety is in focus. Reaching the final is already a significant professional achievement; however, the greatest value lies in the knowledge, experience, and international network the team gained throughout this journey,” said Zsombor Pethő.
The team’s preparation was continuously supported by Prof. Árpád Török, head of the research group.
The participation in Toronto clearly demonstrates that education and research at the Department of Automotive Technologies, BME, are closely aligned with the most pressing international challenges of the automotive industry, while providing students with real opportunities for professional growth and global exposure.
https://auto.bme.hu/wp-content/uploads/2026/05/ESV_presentation.jpg13001625Bognár Bertalan/wp-content/uploads/2024/07/bme-at_logo_white_en01.svgBognár Bertalan2026-05-18 16:51:192026-05-18 17:15:39The BME student team successfully participated in the ESV 2026 final in Toronto
The Safety First! road safety competition, organized by the Department of Automotive Technologies at the Budapest University of Technology and Economics, has reached another milestone this year. Following the first round, the field of advancing teams has been established, and participants are now moving forward with the detailed development of their concepts.
Once again, competitors are addressing current, industry-relevant challenges with innovative solutions. The topics cover a wide spectrum of vehicle safety, ranging from driver monitoring systems and vehicle dynamics to artificial intelligence and cybersecurity.
Advancing teams and their topics:
OrbitDMS Modelling Multi-Sensor Fusion for Driver Monitoring System for takeover readiness
Squadron Reinforcement Learning Based Oversteer Control Under Dynamically Changing Adhesion
secUred 2.0 “Advanced braking system performance and power consumption analysis”
SafeSyncro A Multi-Layered, Proactive Cybersecurity Framework for Software-Defined Vehicles
NOVA Neural Optimization for Verified Automotive Safety
The diversity of the field reflects the complexity of the modern automotive industry: alongside classical vehicle dynamics problems, software-defined systems, automation, and cybersecurity are playing an increasingly prominent role.
The next milestone of the competition will take place on May 8, 2026, when participants are required to submit a detailed 6–10 page technical report. At this stage, teams must go beyond their initial ideas and present the technical foundations, applicability, and—where relevant—model-based validation of their concepts.
“The key to the second round is depth: this is where it becomes clear whether a good idea can evolve into a well-founded engineering concept. Teams need to think not only creatively but also at a system level—this is the point where the competition truly approaches real industrial development processes,” emphasized Tamás Kazár, main organizer of the competition.
The Safety First! competition continues to provide a unique platform for students to develop their ideas along real engineering challenges, supported by both academic and industrial expertise. Throughout the process, participants acquire skills that are directly applicable to future challenges in the automotive industry.
In the coming weeks, the focus shifts to intensive development work behind the scenes—leading up to the final round, where the most promising concepts will once again be presented as tangible, working solutions.
https://auto.bme.hu/wp-content/uploads/2026/04/SF_hir_kep.jpg15361920Bognár Bertalan/wp-content/uploads/2024/07/bme-at_logo_white_en01.svgBognár Bertalan2026-04-09 14:03:572026-04-09 15:59:06Safety First! 2026 – Advancing Teams and Focus on the Development Phase
A student team from the Budapest University of Technology and Economics, affiliated with the Department of Automotive Technologies and BME Automated Drive, has been selected as a European finalist in one of the world’s most prestigious vehicle safety competitions. The final will take place within the framework of the Enhanced Safety of Vehicles Conference in Toronto in May 2026.
The Vehicle Safety and Security Research Group (VSSRG), operating within BME Automated Drive at the Department of Automotive Technologies, has achieved significant international recognition: its student team has been selected as a European finalist for the 10th Student Safety Technology Design Competition.
The competition is part of the 28th ESV Conference, held between May 12–15, 2026, in Toronto, Canada. Co-hosted by the U.S. Department of Transportation’s National Highway Traffic Safety Administration (NHTSA) and Transport Canada, the event brings together leading experts, industry stakeholders, and researchers to advance global vehicle safety.
An Innovative Response to a Critical Safety Challenge
The finalist project, titled “When Cars Talk: V2X-Powered Risk Metrics to Improve Next-Generation Intersection Safety,”
competes in the Advanced Driver Assistance Systems (ADAS) category.
The team members are:
Abdulagha Dadashev
Roland Nagy
Tamás Márton Kazár
Faculty advisor: Zsombor Pethő
The research focuses on road intersections, which remain among the most hazardous environments in traffic systems. A significant proportion of accidents at intersections is caused by limited situational awareness—particularly in blind intersection scenarios—as well as delayed driver reactions, especially in dense urban traffic conditions.
The project addresses a key limitation of current systems: traditional perception sensors and onboard driver assistance technologies alone are not sufficient to fully mitigate these risks. The team explores how Vehicle-to-Everything (V2X) communication can be leveraged to develop advanced risk metrics, enabling cooperative, real-time decision-making and more effective collision prevention.
From Student Innovation to the International Stage
This achievement is the result of a consciously built innovation ecosystem. The VSSRG organizes the annual Safety First! student competition, providing a structured platform for developing and showcasing safety-focused concepts. Beyond fostering new ideas, the initiative also creates pathways to international recognition—clearly demonstrated by this finalist position, as well as previous successes within the competition.
“The next level of road safety will be defined by cooperative systems. Our student team’s work demonstrates that V2X-based approaches are not just theoretical concepts, but can provide measurable contributions to accident prevention. It is particularly important for us that this achievement emerges from a student-driven ecosystem intentionally designed to foster internationally competitive innovation,” said Zsombor Pethő, faculty advisor of the team.
Strengthening BME’s International Presence
Reaching the finals is an important milestone not only for the team, but also for the Department of Automotive Technologies, the Faculty of Transportation Engineering and Vehicle Engineering, and the university as a whole. It reflects the ability of BME’s education and research activities to directly address the most pressing global challenges of the automotive and mobility sectors.
Participating in the finals in Toronto offers a valuable opportunity to present the team’s results to leading international experts and further strengthen BME’s position in the global vehicle safety innovation landscape.
Further updates will follow as the competition progresses.
https://auto.bme.hu/wp-content/uploads/2026/03/Team-c-2-.jpg15361920Bognár Bertalan/wp-content/uploads/2024/07/bme-at_logo_white_en01.svgBognár Bertalan2026-03-31 13:26:312026-03-31 13:26:31BME Student Team Reaches International Finals with a Novel Approach to Intersection Safety




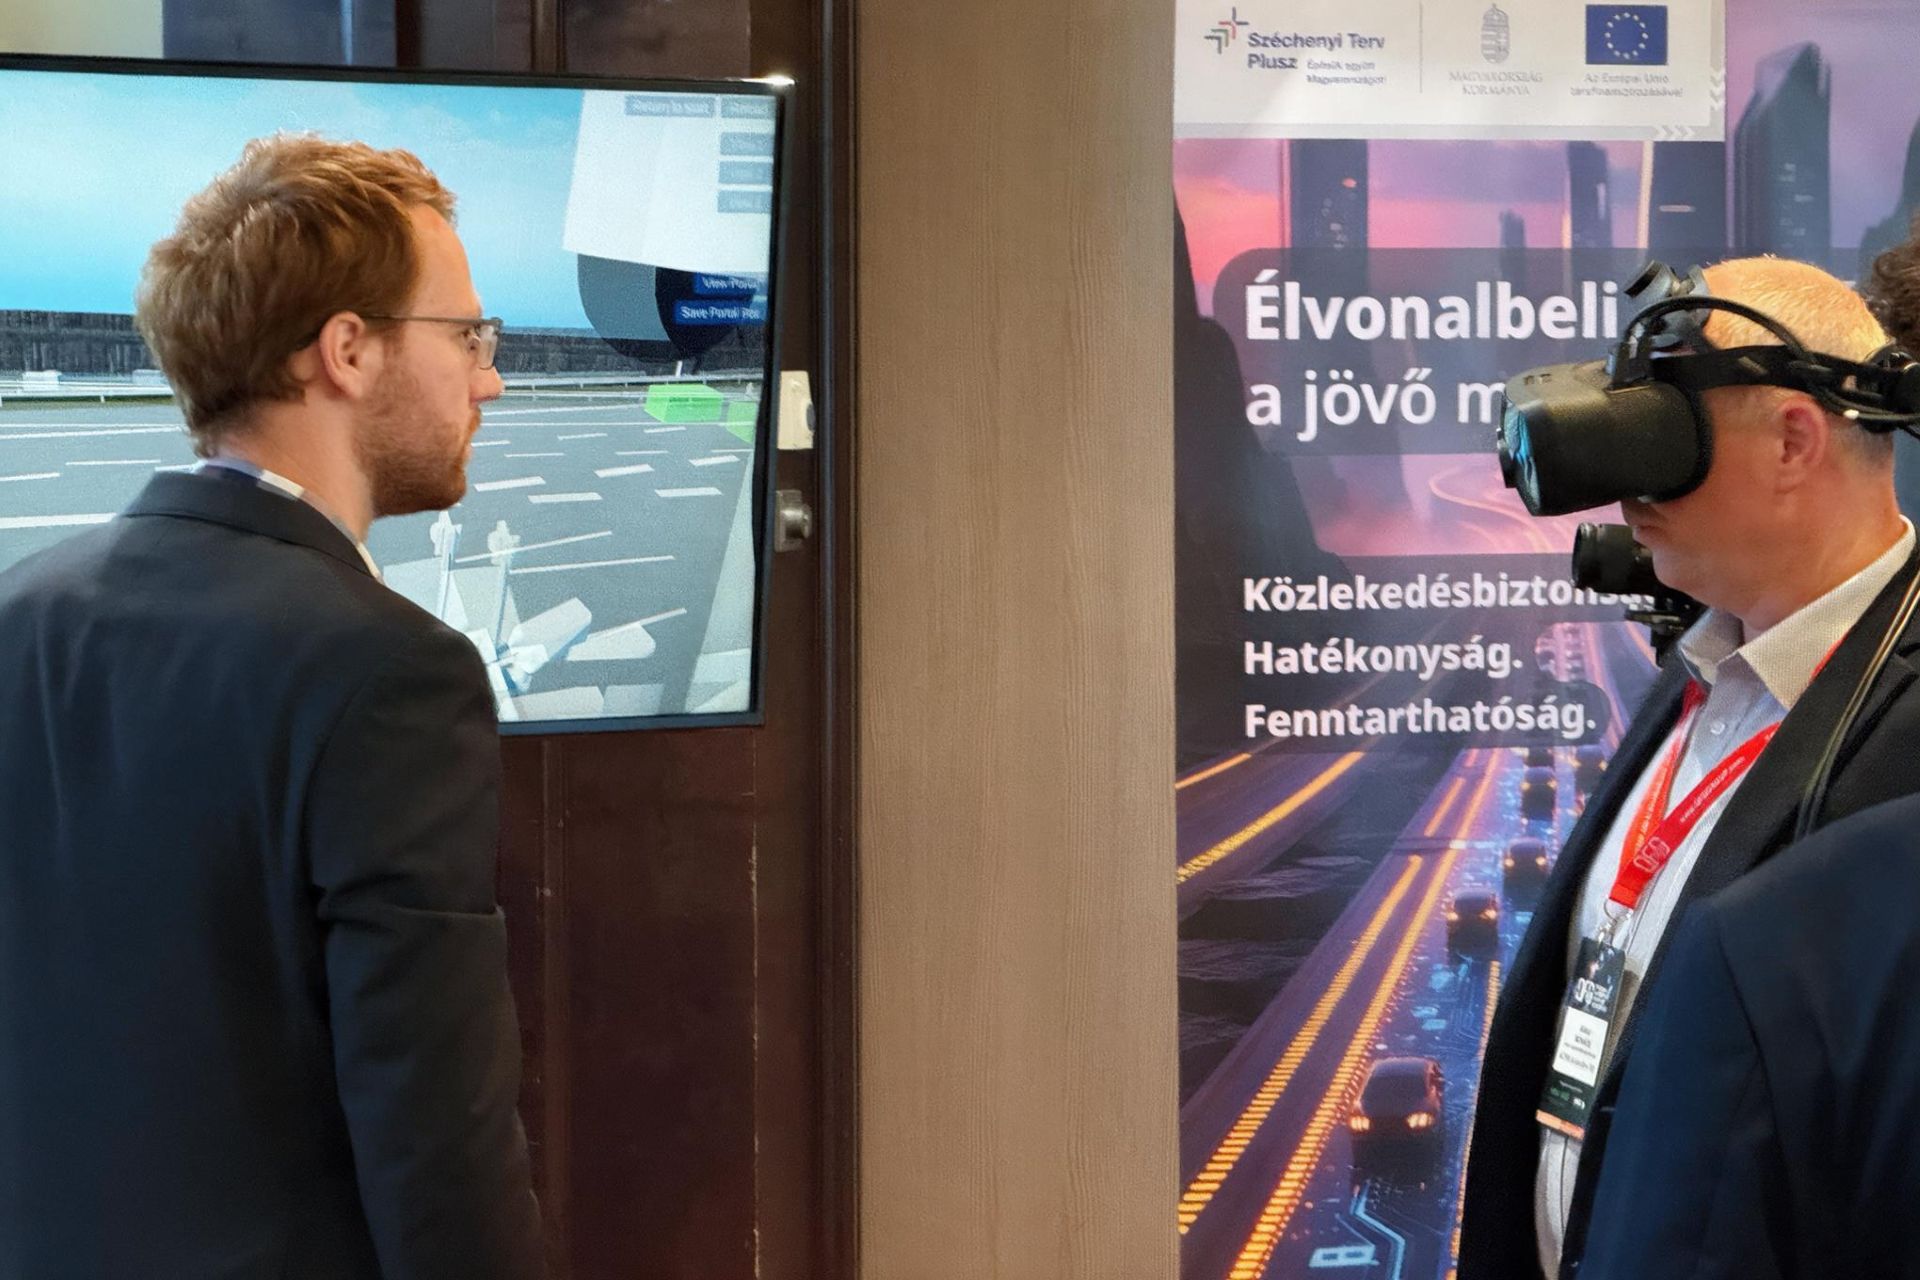
 The BME Department of Automotive Technologies participates as a guest of the Hungarian Public Road Nonprofit Ltd. (Magyar Közút) at its exhibition stand, where the focus is on presenting the M1–M7 smart motorway section and the associated real-time digital twin system. An interactive VR-based demonstration is also available at the stand, providing visitors with an immersive experience of the developed system and its capabilities in representing real-world traffic environments.


