When the Road Starts Thinking – The BME Department of Automotive Technologies Presents the Future of Intelligent Transport Infrastructure at the QFD Conference

Transport infrastructure is not necessarily just the environment in which vehicles operate: with appropriate sensing, data processing and a digital twin, the road itself can become an active, intelligent part of the mobility system. This was the subject of a presentation by Dr. Zsolt Szalay, Associate Professor and Head of the BME Department of Automotive Technologies, at the 15th Regional Automotive Supplier Conference, where the Department also welcomed participants with a live VR demonstration of the M1–M7 smart road digital twin.

The BME Department of Automotive Technologies actively participated in the 15th Regional Automotive Supplier Conference organised by QFD Group in Budapest on 29–30 September 2026. The event brings together automotive decision-makers, OEMs and Tier 1–2 suppliers, as well as representatives of engineering, development and management functions. In addition to industry trends and technological and quality-related challenges, the two-day programme placed strong emphasis on the automotive solutions of the future.

The Department’s participation focused on intelligent transport infrastructure and the digital twin of the M1–M7 smart road. Dr. Zsolt Szalay delivered the conference’s opening plenary presentation, entitled “When the Road Starts Thinking – The Role of Intelligent Transport Infrastructure in Automated Mobility.” In connection with the presentation, participants could also experience the real-time digital twin of the M1–M7 smart road section in a VR environment throughout the day.

What happens when not only the car sees the road?

Dr. Szalay’s presentation started with a simple question: Who sees the road?

For road users, it seems natural that the driver, or the vehicle, perceives the environment. The vehicle’s cameras, radars and LiDAR sensors observe the world around it and use this data to build a model of the traffic situation. This approach, however, has an inherent limitation: the vehicle can primarily work with what it is able to perceive from its own position.

A larger vehicle can obscure the traffic ahead. A bend or a roadside object can conceal an event farther down the road, while in an urban environment, a building may obstruct the detection of a traffic situation developing across an intersection.

What would change if the infrastructure itself could also perceive traffic?

A suitably sensor-equipped road section can observe traffic from a different perspective. Rather than seeing only the immediate surroundings of a single vehicle, it can observe events across an entire road section and process data from different sensors together. This can provide information about traffic situations developing hundreds of metres farther ahead or behind.

This change in perspective leads to the concept of intelligent infrastructure: a public road is not merely the physical environment of vehicles, but can also become part of the sensing and information layer of the mobility system.

The M1–M7 as a real-world research platform

The practical implementation of this concept is demonstrated by the M1–M7 smart road project, in which the BME Department of Automotive Technologies and Magyar Közút equipped an approximately 1.5-kilometre road section with a high-density sensing system.

The road section combines three types of sensing technology: 23 LiDAR sensors, 26 RGB cameras, 10 radar sensors and 10 thermal cameras monitor the traffic environment. The system generates approximately 25 gigabit of data per second, meaning that the data cannot be processed by relying exclusively on a centralised cloud infrastructure. Edge computing capacity deployed along the road complements the cloud-based architecture.

The concept is not limited to data originating from the infrastructure, either. The system can also integrate information from vehicle sensors using wireless communication. This allows the environment perceived by the infrastructure and that perceived by vehicles to become part of a common information system.

In developing the system, the Department also applies standardised data models and communication solutions, including solutions related to the ADASIS and SENSORIS standard families.
From data to a digital twin

One of the most important outcomes of the system is the digital representation of the real road section – the digital twin.

A digital twin is not simply a three-dimensional model. In the case of the M1–M7, real-time detected traffic objects are placed within a highly accurate, static map environment. The static map was created using laser scanning and provides a centimetre-level geometric representation of the road section. On top of this, a dynamic layer of continuously changing traffic information is added.

The physical structure of the road and the traffic taking place on it can therefore be represented simultaneously within the digital environment.

One of the system’s important characteristics is its real-time operation. The Department applies its own artificial-intelligence-based sensor-fusion and vehicle-detection solutions. Information from the different sensors is fused at several levels, and the system can detect vehicles across the entire road section in approximately 30 milliseconds. The complete processing cycle currently takes around 100 milliseconds, allowing the full situation picture to be updated twenty times per second.

This speed enables the digital twin to be more than a retrospective data visualisation: it becomes a system that remains temporally connected to the real traffic situation.

The intelligent road as a digital laboratory

According to Dr. Szalay, one of the most important potential applications of such infrastructure is testing.

Automated-driving and driver-assistance systems are currently typically developed and validated in several stages: in simulation environments, on test tracks and finally in real-world traffic. Real-world traffic testing, however, is costly and time-consuming, while rarely occurring but important traffic situations are difficult to reproduce in a controlled and repeatable manner.

Intelligent infrastructure offers a new possibility here. The M1–M7 smart road can provide highly accurate ground truth, or reference information, in a real traffic environment. This makes it possible, for example, to validate the perception of driver-assistance systems in real time.

The digital twin can take this one step further: real traffic situations can be replayed, repeated and modified virtually. Automated-driving functions under development can therefore be examined not only in simulated, artificial environments, but also using a digital representation of a real road section and real traffic.

In this model, physical and virtual testing are not alternatives to one another, but complementary methods that reinforce each other.

The Department is already investigating this possibility in international collaborations: using simulators at partner universities, it is possible to connect to the current traffic environment of the M1–M7 road section, while the simulated vehicle perceives the representation of real traffic within the digital environment.

The road that remembers

Continuous data collection gives infrastructure another important capability: the road can not only see, but also remember.

If the traffic on a road section is observed over an extended period, the result is not merely a series of isolated traffic events, but a collection of recurring patterns.

It becomes possible, for example, to observe how traffic changes on Monday mornings and Friday afternoons, how rain or fog affects traffic, where congestion regularly develops, and what kinds of traffic situations precede these events.

This makes it possible for the system not only to describe the current traffic state, but also to learn from recurring situations.

Based on large volumes of data, models can also be developed that, initially under human supervision and potentially in the longer term automatically, could support traffic interventions.

A New Dimension to Accident Investigation

A digital twin can also enable an approach to accident investigation that differs fundamentally from conventional on-site procedures. When continuously recorded data from multiple sources are available for the traffic environment, the precise course of an accident can not only be reconstructed afterwards, but its preceding events can also be reviewed and analysed. This means that an investigation does not have to rely exclusively on traces recorded after the accident, the vehicles involved, and witness statements: a digital twin can provide objective, time-stamped and retrievable information that offers a more precise picture of what happened in the seconds leading up to the accident and during the event itself. Another practical benefit could be that traffic restrictions and road closures required for on-site data collection could be partly or even entirely avoided. In this way, a digital-data-based approach to accident investigation could also reduce the time and cost losses resulting from traffic disruption caused by accidents.

We do not need an accident to happen in order to learn from it

One particularly important potential of the digital twin is that lessons do not have to be drawn exclusively from accidents that actually occur.

The same traffic situation can have several possible outcomes. A dangerous situation may lead to an accident on one occasion, while on another occasion the participants may avoid a collision. Such near-miss situations – incidents that almost resulted in an accident – can themselves contain valuable information.

In the M1–M7 system, continuous tracking of the movement of traffic objects makes it possible to identify and analyse such situations. In aviation safety, learning from near misses has long played an important role; intelligent road infrastructure could enable a similar approach in road transport.

Data collected over a longer period can also reveal where and why critical situations repeatedly develop on a particular road section. The knowledge gained in this way can be used not only in operating the given road section, but can also provide valuable input for future infrastructure development and design decisions.

The future cannot simply be predicted – but it can be recognised earlier

The next step discussed in the presentation was prediction.

According to Dr. Szalay, for an intelligent mobility system, the most important objective is not necessarily to “predict the future”. It may be much more important to identify as early as possible the patterns that are likely to lead to congestion, dangerous situations or other undesirable traffic events.

If a change can be detected early enough, intervention can also take place earlier and more preventively.

This is no longer simply traffic monitoring, but decision support: the infrastructure may not only know what is happening, but also indicate the direction in which the traffic situation is developing.

Infrastructure can also extend the capabilities of the car

The digital twin and intelligent infrastructure do not necessarily benefit only the most advanced vehicles.

One of the directions pursued by the Department is to make situation information originating from the infrastructure available through a mobile application also to vehicles that have less advanced sensing capabilities, or no such systems of their own.

Such a solution could, for example, display the position and movement of vehicles detected by the infrastructure even when the vehicle’s own sensors are blocked by another vehicle. This could open up new possibilities in areas such as blind-spot warnings, following-distance recommendations or speed recommendations designed to help prevent dangerous braking waves.

The system could also provide personalised traffic information. Instead of every road user receiving the same general message, the infrastructure could potentially formulate recommendations tailored to the position of individual vehicles.

The next stage of development could be reached when the mobility system not only provides information, but also takes an active role in optimising traffic – for example, by recommending a lane change to some vehicles and a change in speed to others.

New capabilities, new opportunities for suppliers

Technological development also raises an important question for the conference audience, particularly automotive suppliers.

In an intelligent mobility system, value is increasingly created not by individual components in isolation. Sensors, communication systems, computing capacity, artificial intelligence, digital twins and the services built on them jointly create new capabilities.

This may also transform the supplier ecosystem: a component increasingly becomes an enabler of a capability within a larger system.

The supplier of the future will therefore need to do more than deliver a component. Increasingly, suppliers will need to provide technological capabilities, expertise and solutions that can be integrated into a larger system and create value in their own right.

This is particularly important in emerging fields such as intelligent infrastructure, cooperative perception, digital twins, traffic data processing and automated mobility.

Entering the M1–M7 digital twin

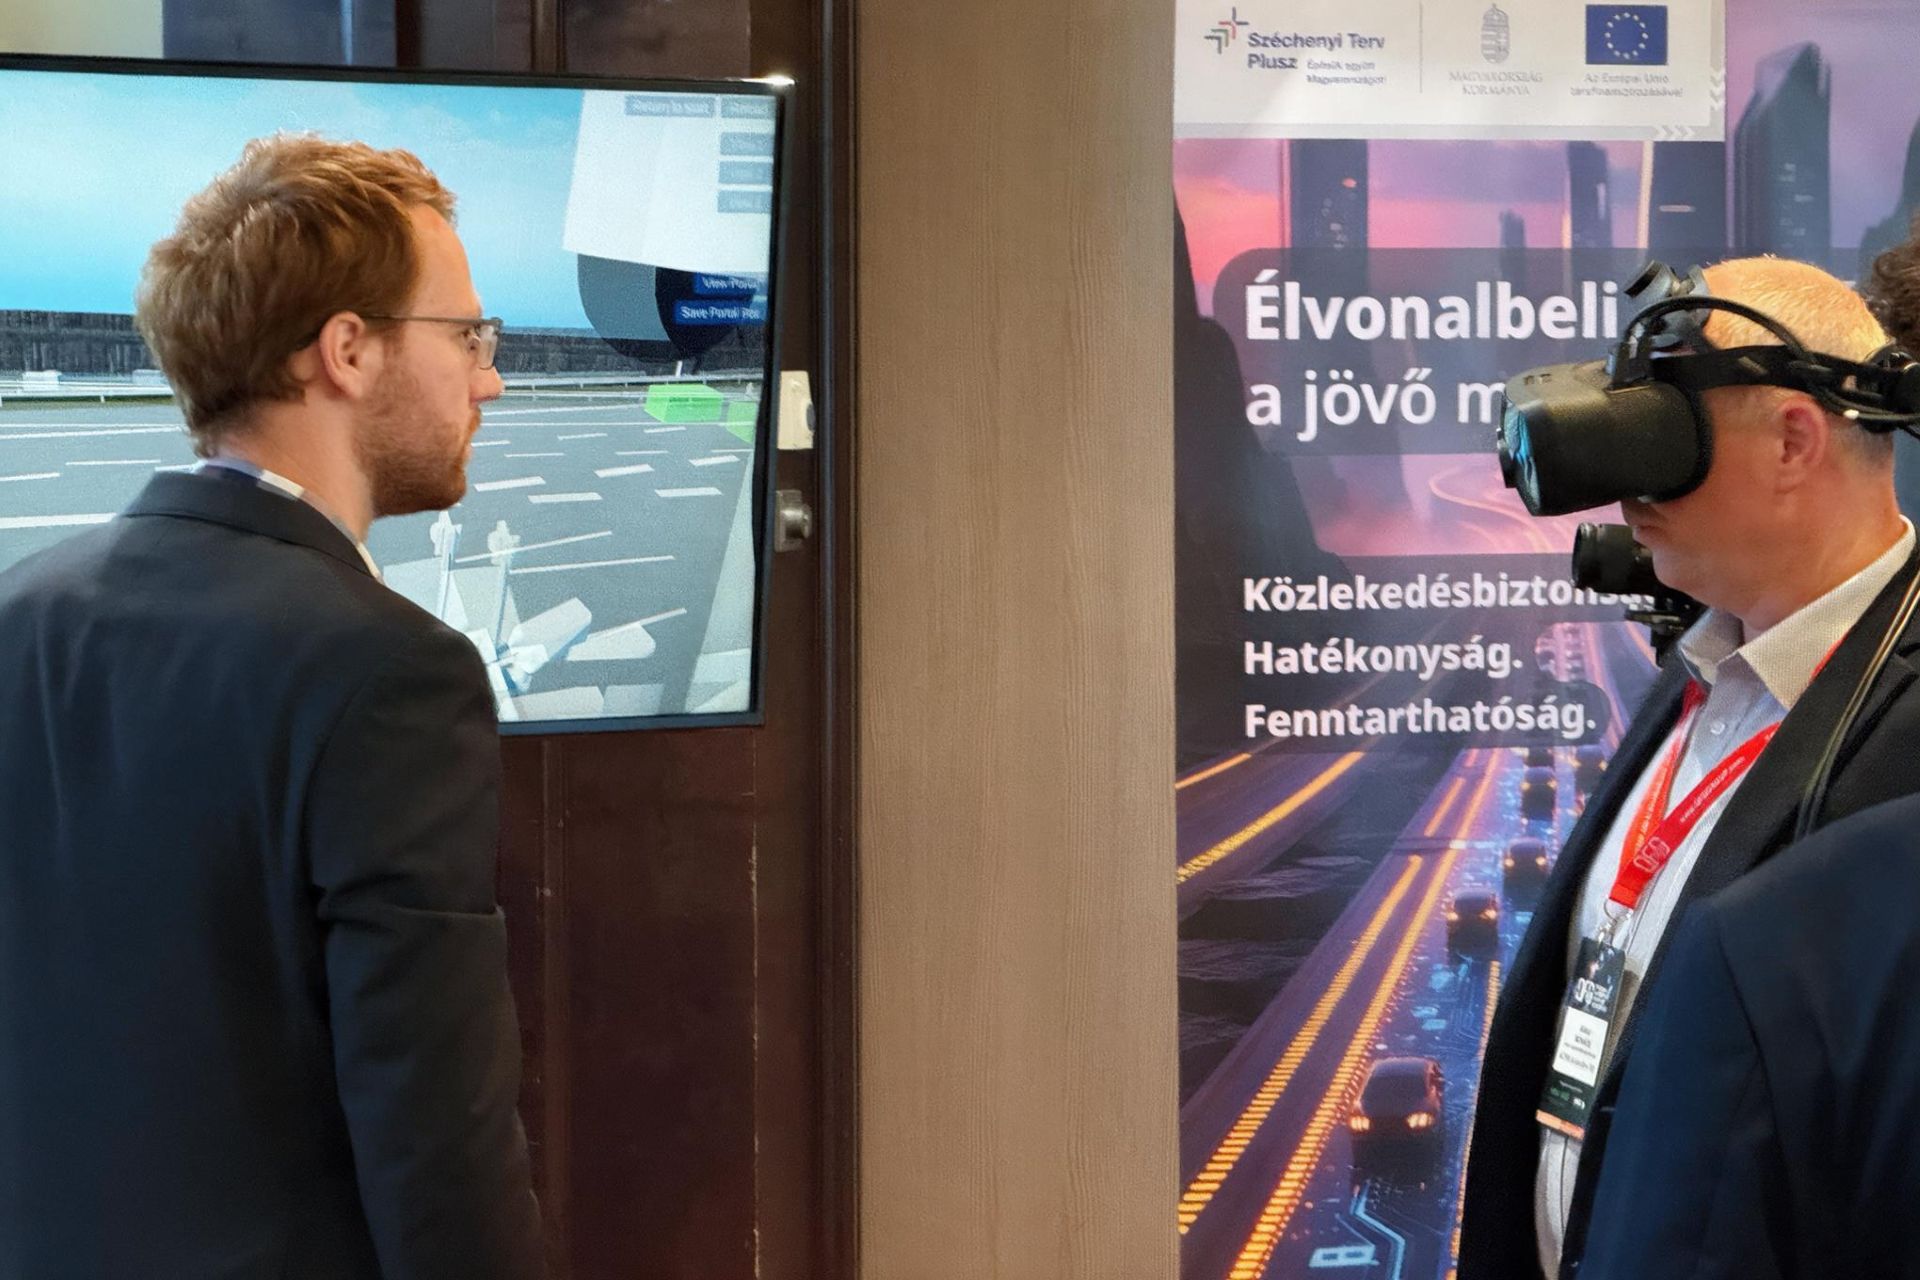
Conference participants could not only hear about intelligent infrastructure in the presentation: at the BME Department of Automotive Technologies’ demonstration area, they could enter the M1–M7 smart road digital twin through a live VR demonstration.

Using VR headsets, visitors could move through the spatial environment of the digital representation of the road section, surrounded by vehicles and traffic events appearing in synchronisation with real-world traffic. The demonstration thus provided a direct experience of one of the digital twin’s essential characteristics: it is not a static 3D model, but a dynamically changing representation based on real-time data streams.

The VR demonstration was part of the QFD Group conference programme throughout the day in the exhibition area, directly complementing Dr. Szalay’s plenary presentation.
The road as an active part of the mobility system

The final message of Dr. Szalay’s presentation was that the development of automated mobility should not be viewed exclusively from the perspective of the vehicle.

Alongside increasingly intelligent vehicles, infrastructure itself can acquire capabilities for sensing, data processing, situation awareness, learning and decision support. The digital twin built on these capabilities can then create a shared information environment for vehicles, infrastructure, road users and service providers.

The next step, therefore, may not simply be an even smarter car.

We are increasingly moving towards a smarter mobility system.

The M1–M7 smart road and digital twin research programme of the BME Department of Automotive Technologies provides a research and demonstration platform for exploring this approach in a real traffic environment. The project simultaneously supports research into intelligent infrastructure, automated mobility, digital-twin-based validation and the future development of the mobility system.

When the Road “Sees” the Vehicle – Testing ADAS with a Digital Twin in Real Highway Traffic

How can the performance of a driver assistance system be evaluated objectively without equipping the vehicle under test with specialized measurement equipment? Experiments conducted on the M1–M7 smart road section by the BME Department of Automotive Technologies explore this question by testing ACC and Lane Centering functions in real highway traffic, using a digital twin generated in real time from infrastructure sensor data.

Testing advanced driver assistance systems (ADAS) in a reliable and meaningful way is becoming increasingly complex. Functions such as Adaptive Cruise Control (ACC) and Lane Centering do not operate in isolation: they continuously respond to a dynamic and changing traffic environment. This makes it increasingly important to complement laboratory and closed proving-ground tests with methods that allow ADAS performance to be evaluated objectively and reproducibly under real road traffic conditions.

Researchers at the BME Department of Automotive Technologies conducted a series of tests on the M1–M7 smart road section to investigate the operation of ACC and Lane Centering in real highway traffic. The distinctive feature of the measurement environment was the simultaneous generation of a digital twin of the road section from the infrastructure’s sensor data in real time. The digital twin represented not only the test vehicles, but also the surrounding traffic with high accuracy.

A total of five test vehicles participated in the measurement campaign, three of which were also equipped with high-precision GNSS systems. These vehicles provided independent reference data for validating the accuracy of the digital twin, including vehicle position, speed, relative distance and motion trajectories.

The tests were conducted in both traffic directions and across all available lanes of the M1–M7 smart road section: four lanes in each direction, eight lanes in total. A key characteristic of the experiments was that they were carried out not in an isolated test environment, but alongside actual highway traffic.

This setting also allowed the researchers to observe not only predefined test scenarios, but naturally occurring and spontaneous traffic events.

“One of the key advantages of the digital twin is that it does not only see the test vehicle, but its entire traffic environment as well. This effectively provides an external reference that makes it possible to objectively evaluate the behaviour of ADAS systems in real traffic.”
– Dr Zsolt Szalay, Head of the BME Department of Automotive Technologies

ACC Response in Controlled and Spontaneous Situations

Several traffic scenarios were developed to investigate Adaptive Cruise Control. In the initial scenarios, the lead vehicle travelled at a constant speed while the ACC system of the following vehicle regulated its speed according to the configured following conditions.

In further scenarios, the lead vehicle performed accelerations and decelerations of varying magnitude. These situations made it possible to analyse the response of the ACC system in detail, including the temporal evolution of following distance and relative speed, as well as how dynamically the system responded to changes in the speed of the vehicle ahead.

At the same time, real traffic introduced situations that could not be fully planned in advance. On several occasions, for example, a vehicle from the public traffic merged into the gap between the two test vehicles.

Although such events caused the measurements to deviate from the predefined test scenarios, they were particularly valuable from a research perspective. Such situations are much closer to the conditions that the ADAS system of a production vehicle may encounter in everyday traffic.

Because the infrastructure-based digital twin also tracks vehicles in public traffic, these spontaneous interactions can be reconstructed and analysed. This makes it possible to determine when, where and how the traffic situation changed, and how the ACC system responded to the new conditions.

Lane Centering: Making In-Lane Vehicle Motion Measurable

During the Lane Centering tests, the researchers analysed vehicle lane-keeping behaviour and in-lane trajectories. Based on the high-precision vehicle trajectories determined by the digital twin, the lateral position of the vehicle within its lane and its evolution over time can be evaluated.

This is particularly relevant for a function whose operation is primarily reflected in the continuous control of the vehicle’s lateral position. An infrastructure-based reference makes it possible to assess vehicle motion independently of the vehicle itself, using an external measurement system.

The approach therefore goes beyond simply “seeing” where a vehicle is travelling. The available data make it possible to quantify the vehicle’s position within the lane and how that position changes over time.

When Traffic Itself Becomes Part of the Test

One of the major challenges of conventional testing is that, in real road environments, other road users can change the conditions in unpredictable ways. In the present measurements, however, this characteristic of real traffic became one of the most interesting research opportunities.

In addition to the test vehicles, the digital twin represented the surrounding public traffic. As a result, an unexpected lane change, a change in speed or another traffic interaction was not simply an “unplanned event”, but became a measurable and analysable occurrence.

“Spontaneous interactions in real traffic do not necessarily disrupt a test – in many cases, they can provide valuable data. With the help of the digital twin, we can also analyse situations that develop unexpectedly during test execution.”
– Dr András Rövid, Head of the Cooperative Perception Research Group

This approach can be particularly important for evaluating highly complex ADAS functions, where system behaviour is often determined by interactions involving multiple vehicles and continuously changing traffic situations.

Digital Twin as a Vehicle-Independent Measurement Reference

One of the key objectives of the experiments was to demonstrate that a digital twin generated in real time from infrastructure sensor data can be used to evaluate ADAS functions against an external, vehicle-independent reference.

The three GNSS-equipped test vehicles provided high-precision reference data that enabled the researchers to verify how accurately the digital twin could determine vehicle positions, speeds, relative distances and trajectories.

The significance of this approach is that, in the longer term, it may eliminate the need to equip every vehicle under test with specialized high-precision GNSS measurement systems in order to obtain objective measurement data.

If infrastructure can reconstruct the motion of traffic participants with sufficient accuracy and in real time, the road itself – more precisely, its intelligent sensor network and the digital twin generated from it – can serve as an external measurement reference system.

This opens up new possibilities for testing ADAS systems on a larger number of vehicles in real road environments. The approach makes it possible to analyse the motion of multiple vehicles simultaneously, the interactions between them, and the responses of driver assistance systems to these interactions.

One Step Closer to Scalable ADAS Testing

The experiments conducted on the M1–M7 smart road section therefore represent more than the evaluation of individual ACC and Lane Centering functions. They also demonstrate a testing and evaluation concept in which real-time infrastructure sensor data, a digital twin and the operation of vehicle-based driver assistance functions are integrated into a common system.

One of the most promising aspects of this approach is its potential to reduce the need for specialized vehicle-side measurement equipment, while enabling the collection of large volumes of objective and comparable test data.

This could become particularly important as ADAS functions and automated driving systems continue to evolve and increasingly complex real-world traffic situations need to be measured, evaluated and compared.

From this perspective, the M1–M7 smart road section is more than an intelligent road. It provides a research environment in which the sensing capabilities of road infrastructure can be directly connected to the objective evaluation of vehicle behaviour – bringing the testing of ADAS functions one step closer to scalable, infrastructure-based validation in real traffic.

Significant Progress in Automated ADAS Test Execution Framework Development by DriveByCloud

The BME Department of Automotive Technologies–affiliated spin-off company DriveByCloud has achieved significant progress in the development of an automated ADAS test execution framework. During a test campaign conducted at the ZalaZONE Proving Ground, the development team successfully continued the system integration activities supporting the realization of automated, repeatable, and efficient vehicle testing processes.

Between 28–30 July 2026, DriveByCloud experts conducted a test campaign at the ZalaZONE Proving Ground with the aim of further developing and integrating the automated ADAS (Advanced Driver Assistance Systems) test execution framework.

The goal of the development is to create a comprehensive system capable of the automated preparation, execution, evaluation, and documentation of ADAS testing processes. During the campaign, two mobile sensor stations equipped with multimodal sensor systems were deployed in the ZalaZONE Smart City module. These stations enabled the system to accurately detect and record the movements of both the test vehicle and the moving platform equipped with a pedestrian dummy involved in the test scenarios.

One of the key capabilities of the developed framework is its ability to import predefined test scenarios and automatically generate scenario variants by modifying different parameters, such as vehicle speed or event timing. The test scenarios to be executed can then be organized into an execution list with predefined numbers of repetitions.

Following test execution, the system automatically evaluates the movement of the vehicle and target objects, as well as the distances between them, based on raw sensor data and user-defined evaluation criteria. Individual test reports are generated based on the evaluated data, providing detailed documentation of each test run. The system then automatically returns the test assets to their initial positions and starts the execution of the next scenario. Summary reports for each scenario type enable efficient statistical analysis of the measured results.

“During the test campaign, we achieved significant progress in system integration. The experience gained greatly supports our further development activities and provides valuable feedback on the practical applicability of automated ADAS test execution processes,” said Zsolt Vincze, scientific assistant at the Autonomous Vehicles Research Group operating within BME Automated Drive and Managing Director of DriveByCloud Ltd.

The test campaign was conducted by DriveByCloud within the framework of a project supported by the National Research, Development and Innovation Office (NKFIH). The work was supported by the expertise and professional collaboration of specialists from the ZalaZONE Proving Ground, the Department of Control for Transportation and Vehicle Systems at BME, and HUN-REN SZTAKI.

This development represents another important step toward automated vehicle testing processes, contributing to the faster, more reliable, and more objective validation of advanced driver assistance systems.

BME PhD Researcher Presented AI-Based Autonomous Drifting Research at the Summer Drift Festival

The latest advances in vehicle control are attracting increasing attention not only in research laboratories and proving grounds but also in the world of motorsport. This was clearly demonstrated by the participation of the Department of Automotive Technologies at the Budapest University of Technology and Economics (BME) in the 2026 Summer Drift Festival, where the department’s joint research with HUN-REN SZTAKI was introduced to the professional drifting community.

On 11 July 2026, Szilárd Hunor Tóth, a PhD researcher at the BME Department of Automotive Technologies and Research Assistant at the Intelligent Processes Research Group of HUN-REN SZTAKI, delivered a presentation during the professional workshop of the Summer Drift Festival held at RabócsiRing in Máriapócs. Organized by HUNAKAMO as part of the international Drift Kings Championship, the workshop was primarily intended for professional drivers, mechanics, team members, and other experts involved in competitive drifting.

The presentation showcased the latest achievements of the joint AI-based autonomous drifting research conducted by the BME Department of Automotive Technologies and HUN-REN SZTAKI. The project focuses on developing intelligent vehicle control solutions capable of maintaining stable and precise control of a vehicle operating at the limits of tire adhesion under highly dynamic conditions. Building upon the team’s internationally patented model-based control approach, the research has now been extended with reinforcement learning-based artificial intelligence methods, enabling increasingly capable autonomous drifting performance.

One of the project’s most significant milestones is that the AI-based control system has been successfully demonstrated not only in simulation but also on a real vehicle, confirming the practical feasibility of the proposed approach. The research is carried out within the framework of the National Laboratory for Autonomous Systems, under the leadership of Dr. Zsolt Szalay, Head of the Department of Automotive Technologies at BME.

The workshop provided a unique opportunity for professional drifters, mechanics, engineers, and team members to gain first-hand insight into the objectives and achievements of the research. Many participants were particularly interested in how motorsport expertise and state-of-the-art artificial intelligence techniques can be combined to advance the development of future autonomous vehicles. According to the feedback received, many attendees were surprised to learn that such advanced research on autonomous drifting is already being conducted in Hungary under the leadership of BME.

The event highlighted how the BME Department of Automotive Technologies, together with HUN-REN SZTAKI, is successfully connecting cutting-edge academic research with the practical world of motorsport. These collaborations create valuable opportunities to validate research results in real-world environments while allowing experiences from competitive drifting to inspire the next generation of autonomous vehicle technologies.

The research team plans to continue these professional outreach activities at future rounds of the Drift Kings Championship, with the next presentation expected to take place at the Trackwood #15 Drift Festival on 29 August 2026.

Beyond the Final Examination – What Do Industry Experts Look For?

An MSc final examination is not only an opportunity for students to demonstrate their knowledge. For the industry representatives serving on the examination committee, it is also a valuable opportunity to gain first-hand insight into the preparedness of the next generation of engineers. We spoke with János Dániel Füzesi from Robert Bosch Ltd. and Zoltán Somogyi from AVL Hungary about their impressions of this year’s examinations, the qualities they look for in early-career engineers, and how they assess the students of the Department of Automotive Technologies at BME.

According to both industry representatives, a final examination reveals far more than a student’s ability to deliver a polished presentation.

For János Dániel Füzesi, the most important aspect is the candidate’s way of thinking.

“A well-structured thesis clearly demonstrates how the candidate approached the problem, how systematically they worked through it, how they arrived at their solution, and whether they maintained an engineering mindset throughout the entire process. That tells us much more about their real capabilities than presentation skills alone.”

He also pointed out that confidence by itself is not enough.

“Some people are naturally excellent presenters, while others are quieter and more reserved. What defines a good engineer is not personality, but the ability to stand behind their own work with credibility and solid technical substance.”

Zoltán Somogyi highlighted another equally important aspect.

“Engineers are often naturally introverted. Nevertheless, today it is essential that they can communicate and defend their own results. Modern automotive development is fundamentally teamwork, so communication is no longer an ‘extra skill’—it has become an integral part of engineering.”

He also emphasized the importance of systems thinking.

“We wanted to see whether students could step beyond the details of their thesis and place their work into a broader engineering context. That is why many of our questions went beyond the specific technical results.”

Positive surprises

Both experts agreed that the students exceeded their expectations in several respects.

For Zoltán Somogyi, the quality of the presentations was particularly impressive.

“When I graduated, presentation skills received far less attention than they do today. This time we saw presentations with clear structure, well-designed slides and effective visual communication. AI tools are probably helping students prepare more professional presentations as well.”

For János Dániel Füzesi, one of the most inspiring aspects was the diversity of perspectives brought by the international students.

“It was fascinating to see how students from different countries approached different challenges. One thesis, for example, explored the second-life use of electric vehicle batteries in residential energy storage systems. These different perspectives always enrich engineering thinking.”

What does industry look for today?

When asked to identify the single most important quality in a young engineer, both experts gave remarkably similar answers.

For Zoltán Somogyi, it is systems-level analytical thinking.

“Today, AI can provide enormous amounts of information within seconds. What distinguishes a good engineer is the ability to understand relationships, think systematically and approach problems in a structured way.”

János Dániel Füzesi focused more on personal qualities.

“Curiosity and the desire for continuous learning are probably the most valuable characteristics. It is equally important to have the humility to recognize that earning a degree is not the end of learning—it is the beginning of a new stage of professional development.”

Being an engineer in the age of AI

Naturally, the conversation also turned to artificial intelligence.

Both experts agreed that AI will fundamentally reshape engineering work, making it increasingly difficult to predict which tasks will remain exclusively human in the long term.

However, they were equally convinced that identifying the right problems, asking the right questions, and defining development goals will continue to be core engineering responsibilities.

“AI can become an excellent professional assistant, but engineers must still decide which problems are worth solving and what constitutes a successful solution,” said Zoltán Somogyi.

Why does industry participation matter?

Towards the end of the discussion, we also asked why it is important for industry representatives to participate in final examination committees.

According to János Dániel Füzesi, their presence sends an important message in itself.

“Having industry representatives on the examination committee demonstrates that the final examination extends beyond the university. It not only adds further recognition to students’ achievements but also creates an opportunity for mutual learning between academia and industry, strengthening the partnership between them.”

Zoltán Somogyi added that these examinations also provide valuable feedback for industry.

From this year’s experience, he found it particularly encouraging that the thesis topics addressed challenges currently faced by the automotive sector, while students demonstrated increasing confidence in using simulation environments, programming tools and advanced engineering software.

By the end of the examination day, it was not only the students who received valuable feedback on their performance. The industry representatives also left with a clear impression that the Department of Automotive Technologies at BME is educating engineers who are working on relevant, up-to-date topics, are capable of systems-level thinking, and are becoming increasingly confident in presenting and defending their own engineering work.

Where Does an Engineering Career Begin? – Dr. Zsolt Szalay Inspires a New Generation at BME Children’s University

An engineering career may not begin at university—it may begin years earlier, sparked by a fascinating lecture, an unexpected question, or an inspiring encounter with technology. For many children attending this year’s BME Children’s University, that first spark may have been ignited during a lecture on the future of autonomous vehicles.

The 2026 BME Children’s University once again welcomed hundreds of curious children aged 8–14 to the Budapest University of Technology and Economics. Designed to provide a genuine university experience, the five-day programme combines large lectures with hands-on activities, allowing participants to explore the world of engineering and science in an engaging and inspiring environment.

The Department of Automotive Technologies contributed to this year’s programme through a lecture delivered by Dr. Zsolt Szalay, Head of the Department and leader of BME Automated Drive. His presentation took the audience on a journey through the evolution of self-driving vehicles, explaining how autonomous technologies have developed and what challenges and opportunities lie ahead.

The lecture attracted considerable interest, with the young audience following the presentation with remarkable attention. Discussions on artificial intelligence, future mobility, and autonomous driving clearly captured their imagination.

The conversation did not end when the lecture was over. Many children gathered around Dr. Szalay afterwards to continue asking questions, eager to learn more about autonomous vehicles and the technologies shaping the future of transportation. Their curiosity and surprisingly well-informed questions once again demonstrated how naturally younger generations engage with emerging technologies.

“The Children’s University is one of the highlights of my year. It is always inspiring to meet young people who are genuinely curious, eager to ask questions, and excited about discovering how technology works. These conversations remind us why it is so important to introduce science and engineering at an early age,” said Dr. Zsolt Szalay.

Dr. Szalay has been a regular speaker at the BME Children’s University since the programme was launched. Over the years, he has introduced hundreds of children to the exciting world of future mobility and automotive engineering.

It would be fascinating to know how many of today’s BME students first encountered automotive engineering through a Children’s University lecture years ago. Perhaps some of this year’s enthusiastic participants will one day return to the Department of Automotive Technologies—not as visitors, but as university students ready to help shape the future of mobility.

If this year’s lecture inspired even a handful of children to imagine themselves as future engineers, then it has already achieved one of the programme’s most meaningful goals.

“From Two Countries Toward a Shared Goal” – Snapshots from the Final Master’s Examination at the Department of Automotive Technologies

The final examination is always a special day. Months – sometimes years – of work are condensed into a few minutes, when students are expected to demonstrate not only their knowledge, but also their professional thinking and independent problem-solving skills. After the examinations, and before the results were announced, we spoke with two graduating students about how they experienced this day, what the Department of Automotive Technologies at BME meant to them, and what kind of engineers they aspire to become.

For Ahmed Waleed Mohamed Kamel Mohamed, the first moments of the examination were primarily defined by tension. Although he knew he would be presenting his own work, stepping in front of the examination committee still represented a serious challenge.

“It was stressful to enter the room, but I knew I had to trust my own work. I had prepared my thesis from A to Z, and that gave me confidence.”

One question, in particular, remained memorable for him: when he was asked whether the work was truly his own. Although it briefly unsettled him, he later felt that it gave him an opportunity to demonstrate his preparedness.

“For a moment the question stopped me, but in the end I was glad it came up. It felt good to show that I had indeed done this work myself.”

Arbër Kopani arrived at the examination in a somewhat calmer state of mind. Having already obtained a bachelor’s degree in Hungary, the examination situation itself was not unfamiliar to him.

“Of course I was a bit nervous, but I roughly knew what to expect. When the theoretical part was over, I felt for the first time that everything would be fine. We had been working on the thesis for months, so we know it best.”

The two students arrived in Budapest from different countries: Ahmed from Egypt and Arbër from Albania. Both feel that BME provided them not only with professional knowledge, but also with significant personal development.

Ahmed had previously completed his bachelor’s studies in Ukraine, which gave him a direct basis for comparison.

“The biggest difference for me was that here we received much more confidence. The continuous presentations and the opportunity to present our own work significantly improved my confidence. Today I can stand in front of people and present what I have done much more comfortably.”

He also emphasized the strongly practice-oriented approach of the department.

“It was very inspiring to see that we are not only learning theory here. We worked with real vehicles, in laboratories, and through experiments. When you can test a development in a real environment, that is when knowledge becomes truly tangible.”

For the student arriving from Egypt, one of the most important outcomes of studying abroad was not even professional.

“Studying with people from different cultures made me realize that we actually have much more in common than differences. We speak different languages and have different traditions, but we experience the same feelings.”

For Arbër, the most memorable aspects were rather the key academic decision points. Choosing a specialization and defining the thesis topic, in his view, largely determines one’s future professional direction.

“The thesis topic is essentially about what you want to work on in the coming years. It is one of the most important decisions in the whole program.”

He also highlighted the importance of courses that included exposure to industrial environments.

“When we visit companies and see how a development team or an organization works, it becomes much easier to imagine what it will be like to work as an engineer.”

Both students feel that their university years contributed not only to their technical knowledge.

For Ahmed, the most significant change was in his presentation skills.

“I could not present like this before. At BME we had many opportunities to present our work, and this brought enormous improvement.”

Arbër emphasized teamwork and leadership skills.

“During group assignments we often had to take on leadership roles. We learned to work more independently, collaborate, and take responsibility. These are skills we will definitely use in our future jobs.”

When asked whether they currently feel more like students or engineers, their answers differed notably.

Ahmed stated firmly:

“I feel like an engineer. But I will only call myself a real engineer when I create something that brings real value to society.”

Arbër, in contrast, still considers this a transitional phase:

“At the moment I still feel more like a student. I think I will truly feel like an engineer when I start working, gain experience, and take responsibility for a team.”

Their visions for the future are nevertheless similarly focused. Ahmed aims to work with embedded systems and research and development, preferably in Hungary. Arbër, in the longer term, aims to lead a development team.

When asked what advice they would give to younger students, both shared concise but meaningful messages.

Ahmed’s advice is simple:

“Do your best, believe in yourself, and you will succeed.”

Arbër encourages future students to choose a specialization aligned with the most recent trends in the automotive industry – including automation, electric vehicles, and autonomous systems.

At the time of the interview, the results of the final examination were still unknown. Ahmed and Arbër had already completed their own examination parts and spoke during the quiet waiting period about how they experienced the day. Their answers revealed two distinct self-perceptions: one of them already sees himself as an engineer, while the other considers this role as a next stage still ahead. What they shared, however, was the atmosphere of the day – the sense that behind a completed examination, an open professional journey was just beginning for both of them.

BME Department of Automotive Technologies Receives Advanced BMW Diagnostic System

On June 5, the collaboration between the BME Department of Automotive Technologies and BMW Group reached another important milestone as representatives of BMW Group Hungary officially handed over an advanced diagnostic system, the ICOM device, to the department.

Representing BMW Group Hungary at the handover ceremony were Évi Csomor, Training and Retail HR Manager at BMW Group Hungary, and Róbert Rák, Head of Customer Support at BMW Hungary. The department was represented by Dr. Zsolt Szalay, Head of the Department of Automotive Technologies, and Márk Lelekes, Head of the Innovative Vehicle Technologies Research Group, who received the equipment on behalf of the department.

The advanced ICOM diagnostic system complements the MINI Countryman vehicle previously provided to the department by BMW Group and enables high-level access to the vehicle’s communication systems. The equipment allows detailed analysis of various vehicle subsystems, including battery systems, energy management functions, and other key onboard systems.

The support provided by BMW Group aligns closely with the department’s strategic objective to become one of BME’s leading centers of excellence in the education and research of zero-emission and low-carbon mobility systems. The new equipment represents a significant and highly advanced resource for both education and research activities.

“Providing education for the next generation of vehicle technologies requires that our students work with state-of-the-art industrial tools and real vehicle systems. The ICOM diagnostic system offers an exceptionally deep level of access to the communication and energy management systems of modern vehicles, making it highly valuable for both education and research. Our goal is to integrate these tools into education from the next academic year and to further strengthen our collaboration with BMW Group,” emphasized Dr. Zsolt Szalay, Head of the Department.

According to the department’s plans, the new diagnostic system will already be integrated into educational activities from the next academic year, enabling students to gain direct hands-on experience with the operation and diagnostic processes of modern electrified vehicle systems.

From a Rolling Headlight Trim to the Frontline of European Accident Investigation – A Feature on Dr. Gábor Melegh, Former Head of Our Department

Where does a detached headlight trim roll after a traffic accident? At first glance, it may seem like an insignificant technical detail. Yet in reconstructing a road accident, it can become a decisive question. More than five decades ago, it was precisely a problem like this that launched the professional journey of Dr. Gábor Melegh, retired lecturer, former Head of the Department of Automotive Technologies at BME, honorary university professor, and still an active educator today, who would go on to become one of Hungary’s and Europe’s leading authorities in traffic accident analysis.

Recently, Autószektor published an in-depth feature article about the honorary professor of our department. The publication provides an excellent opportunity to reflect on the milestones of an exceptional career that has shaped not only Hungarian forensic traffic accident investigation for decades, but has also had a lasting impact on the development of our department.

Dr. Gábor Melegh headed the Department of Automotive Technologies at the Budapest University of Technology and Economics between 2002 and 2012. Under his leadership, the department further strengthened its position in both education and research, while he simultaneously built a professional career whose significance extended far beyond the university.

Holding a doctoral degree in transportation sciences, he has prepared more than 25,000 forensic expert reports, including approximately 15,000 criminal traffic accident cases and 10,000 civil cases. As a forensic expert, he participated in the investigation of several major transportation tragedies in Hungary — from the Pörböly school bus tragedy to the bus accidents in Taszár and Agárd — while also contributing to the analysis of accidents involving senior public figures and politicians.

However, the significance of his work lies not merely in the number or prominence of the cases, but in the engineering mindset he consistently represented: the precise interpretation of details, the systematic evaluation of physical evidence at accident scenes, and the pioneering use of computer simulations in accident reconstruction. At a time when such methods were far from commonplace, he was already developing his own software programs to support accident analysis.

Another defining dimension of his professional legacy is knowledge transfer. Dr. Melegh played an active role in establishing postgraduate university training for forensic traffic experts and contributed to the development of educational materials and textbooks that have become foundational references for generations of professionals. It is a particular privilege for our department that, even after retirement, he continues to participate in teaching, passing on decades of accumulated expertise and experience to future engineers and specialists.

Perhaps those who have known him as a mentor, colleague, and friend can best capture the true impact of his work.

“For me, he has been a teacher, colleague, and friend in one person. More than 35 years ago, he supervised my university work, and later we had the opportunity to work together. His professional knowledge is invaluable, and he has always been exemplary both in his profession and in his personal life,” said Dr. Gábor Vida, lecturer at our department and forensic expert.

Dr. Melegh has also played a significant role in the international development of the field. He contributed to the harmonization of European accident investigation methodologies, played a founding role in establishing the European Association for Accident Research and Analysis (EVU), and held leading positions in several Hungarian forensic expert organizations.

For the Department of Automotive Technologies at BME, educators who combine high-level engineering expertise with a deep sense of social responsibility represent a particularly important value. The forensic investigation of road accidents is far more than a technical exercise: it helps establish the foundation for legal decisions affecting human lives, enables lessons to be learned, and ultimately contributes to preventing future tragedies.

The Autószektor feature pays tribute to an extraordinary professional career. For us, it also serves as a reminder of the lasting value created when a department is shaped — and continues to be enriched — by professionals whose knowledge, integrity, and commitment leave a mark across generations.

Safety First! 2026 – Transportation Safety Innovation Competition Concludes for the Fourth Time

The Safety First! 2026 transportation safety competition, organized for the fourth consecutive year by the Department of Automotive Technologies at the Budapest University of Technology and Economics (BME) and its Safety and Security Research Group, has successfully concluded. At this year’s final round, student teams presented the research and development results they had been working on throughout the semester, offering innovative responses to real-world vehicle safety challenges.

Since its launch, the goal of the Safety First! competition has been to provide students with an opportunity to work on real engineering problems while developing their professional skills with both academic and industrial support. Throughout the multi-stage competition, participants are expected not only to develop technically sound concepts, but also to demonstrate their applicability and present their results in a professional manner.

In the final round, projects were evaluated by an expert jury based on five key criteria: the quality of the abstract, the technical standard of the documentation, the level of innovation, project maturity, and the quality of the oral presentation.

Innovative Solutions for the Future of Vehicle Safety

This year’s competition once again reflected the technological diversity of today’s automotive industry, covering topics ranging from vehicle dynamics and artificial intelligence to driver monitoring systems and the verification of safety-critical functions.

🥇 1st Place – Squadron

Reinforcement Learning Based Oversteer Control Under Dynamically Changing Adhesion

The winning team introduced a hybrid Model Predictive Control (MPC) and Reinforcement Learning-based vehicle stability solution capable of adaptive intervention under rapidly changing road adhesion conditions. The system supports safe vehicle control through real-time decision-making and demonstrates promising applicability in advanced driver assistance systems (ADAS) and fleet-level safety applications.

🥈 2nd Place – NOVA

Neural Optimization for Verified Automotive Safety

The second-place project addressed a particularly timely challenge: how to reconcile the performance of neural networks with the strict verification requirements of automotive safety-critical systems. The team presented an innovative concept combining the trainability of AI-based vehicle functions with validation and certification considerations.

🥉 3rd Place – OrbitDMS

Modelling Multi-Sensor Fusion for Driver Monitoring System for Takeover Readiness

The third-place team focused on one of the key challenges of partially automated driving: how to reliably determine whether a driver is ready to take back control of the vehicle. Their multi-sensor fusion approach could contribute to safer transitions between automated and manual driving.

Real Industry Perspective, Practical Experience

The competition once again demonstrated that students are capable of addressing today’s automotive challenges at a remarkably high professional level. The presented projects stood out not only for their technical depth and practical relevance, but also for the mature, systems-level engineering mindset demonstrated by the participants.

“One of the greatest strengths of the Safety First! competition is that it gives students the opportunity to challenge themselves in an environment that closely resembles real industrial development processes. Beyond technical content, problem definition, high-quality documentation, and professional presentation skills are equally important,” highlighted Tamás Kazár, chief organizer of the competition and PhD researcher of the Safety and Security Research Group at the BME Department of Automotive Technologies.

Acknowledgements to Our Supporters and Jury Members

This year’s competition was once again supported by our industrial partner, Bosch, whose expert involvement provided students with direct insight into industrial expectations and development perspectives.

We would also like to express our sincere appreciation to the members of the professional jury for their valuable feedback and dedicated work:

  • Réka Jenei (Bosch)
  • Tamás Kazár (BME KJK, Safety and Security Research Group)
  • Árpád Török (BME KJK, Head of the Safety and Security Research Group)

We warmly congratulate all participants for their hard work and dedication, and especially the finalist teams for their outstanding achievements.

Over the past four years, the Safety First! competition has evolved into a unique professional platform where students not only compete, but also develop genuine engineering thinking, presentation skills, and an industry-oriented mindset. We are already looking forward to the innovative ideas and new challenges of next year’s competition.